TYPE
Simulation · ROS 2 Jazzy + Turtlesim
RESULT
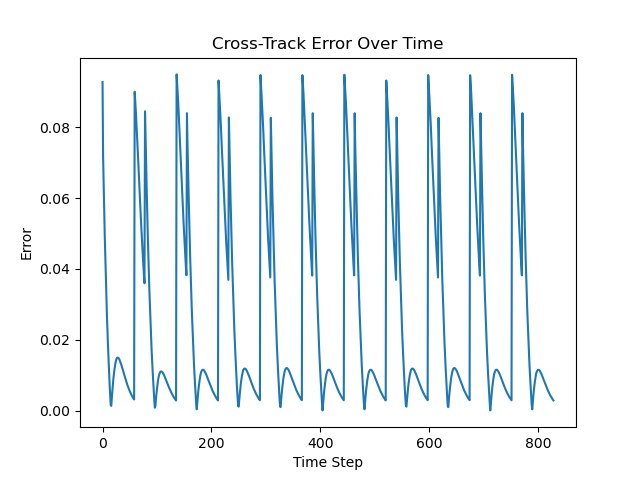
Avg cross-track error 0.760 to 0.027
THE FIX
Structure, not gain tuning
Overview
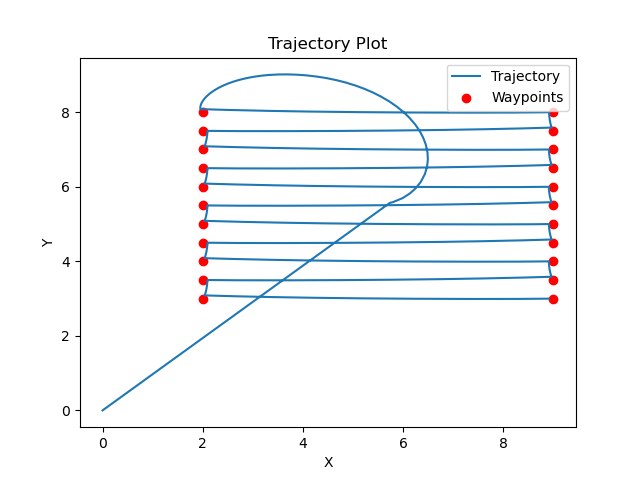
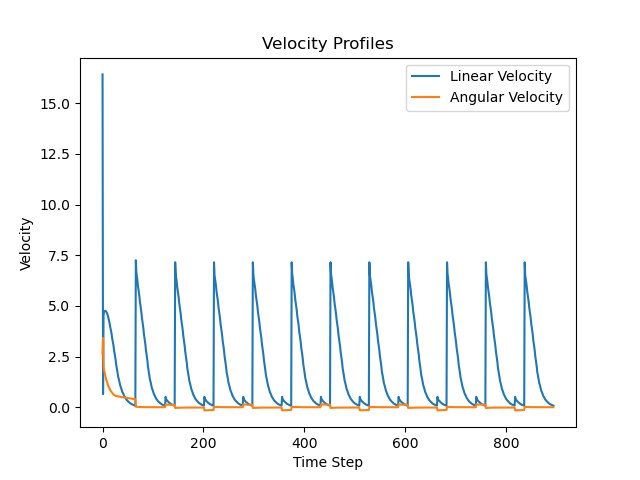
- The provided coupled PD controller drew spirals: 0.76 average cross-track error no matter the gains. The diagnosis was structural, so the fix was structural: a TURN and DRIVE state machine that rotates in place before every segment and never steers while turning.
Design & Build
- Controller: A finite state machine alternating pure rotation and pure translation, with signed cross-track error computed by vector projection with numerical guards.
- Waypoints: The generator was rewritten to produce orthogonal rows with vertical step downs at the edges instead of diagonal transitions.
- Instrumentation: A custom ROS 2 performance metrics message, the assignment's extra credit item.
Challenges
- Recognizing that no amount of PD tuning fixes a controller that couples heading and translation through every segment change.
Result
- Average cross-track error cut 96.5 percent, from 0.760 to 0.027 units, maximum from about 2.0 to 0.10, across all 22 waypoints.
Skills & Tools
ROS 2 JazzyControl DesignState MachinesPythonTurtlesim