TYPE
Mobile manipulation · Optimal control
ROLE
Solo: modeling to LQR benchmark · Advanced System Modeling & Control
STACK
MuJoCo · MATLAB · Python · 8 DOF
Overview
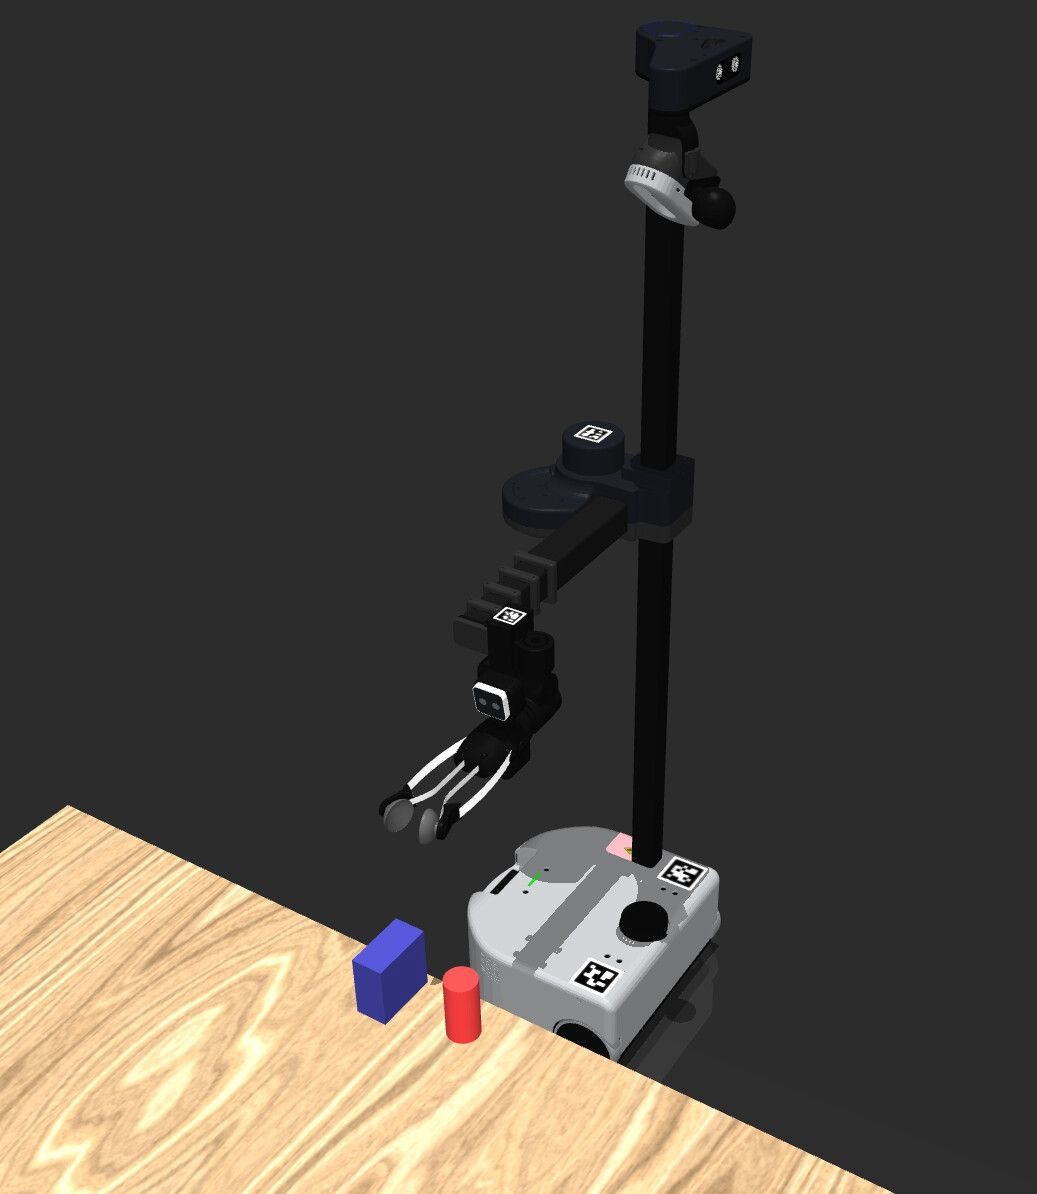
- Fixed-base industrial arms do pick-and-place precisely, but they are locked into fixed workcells and fixed capital. This project explores the flexible-automation alternative: Hello Robot's Stretch3 mobile manipulator, simulated in MuJoCo, picking and placing a cuboid and a cylinder anywhere its base can drive.
- Under the simulation sits the control theory. The lift and arm extension were modeled as a six-state state-space system, built symbolically in MATLAB and formally checked for controllability, observability, and stability, then a PD controller drove all eight degrees of freedom and an LQR took on the modeled axes to see how much performance optimal control buys.
Design & Build
- Model: Lift and arm extension as mass-spring-damper joints with first-order actuator dynamics: six states, two inputs, with the A, B, C, D matrices constructed symbolically in MATLAB from assumed numerical parameters.
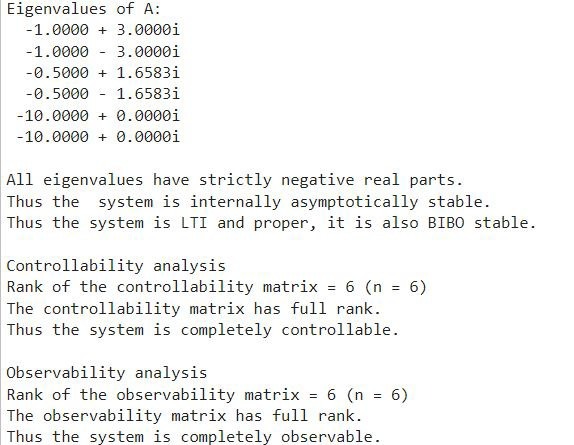
- Proof: Controllability and observability matrices both computed at full rank six, every eigenvalue of A with strictly negative real part: the modeled system is controllable, observable, asymptotically stable, and BIBO stable.
- Control: A Python PD controller drives all 8 DOF of Hello Robot's Stretch3 MuJoCo model - base x and y, prismatic lift, telescopic extension, three wrist axes, and gripper - with gains tuned iteratively in the model XML.
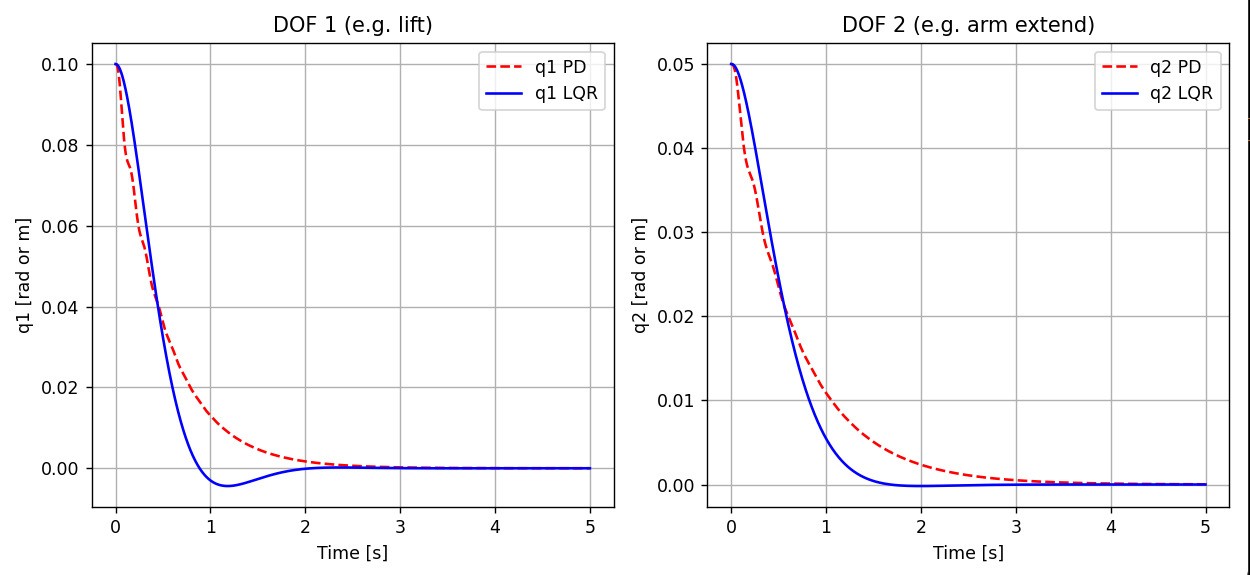
- Benchmark: An LQR designed on the two modeled axes as a proof of concept, its Q and R weights tuned for speed, then compared head-to-head against the PD on the same step response.
Challenges
- Tuning eight joints at once: each stiffness-damping pair traded speed against overshoot, and pick-and-place punishes both the slow and the bouncy.
- Keeping the analytical model tractable - reducing eight degrees of freedom to the two that carry the pick height and reach without losing the structure worth proving things about.
- Grasping under contact: closed-loop feedback at every simulation step so the robot compensates for small disturbances and contact forces instead of fumbling the object.
Result
- Complete pick-and-place of both objects in MuJoCo with all eight degrees of freedom driven by the tuned PD controller.
- The modeled system formally shown controllable, observable, asymptotically stable, and BIBO stable in MATLAB - the analysis that argues the concept is fit to carry onto Stretch3 hardware.
- The LQR settled faster than the tuned PD at higher control aggressiveness, with a small undershoot on the lift - and MPC and hardware validation flagged as the next steps.
Skills & Tools
State-Space ModelingMATLABMuJoCoPythonPD ControlLQRControllability & ObservabilityStability Analysis